Sixteen standard cup positions are divided across four independently controlled channels. Use only the zones that contact the workpiece, adjust the cup layout, or control channels separately for different box sizes and pickup patterns.

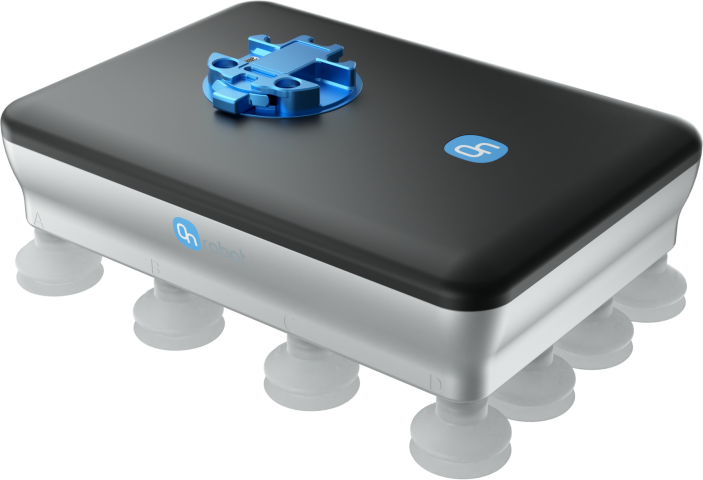
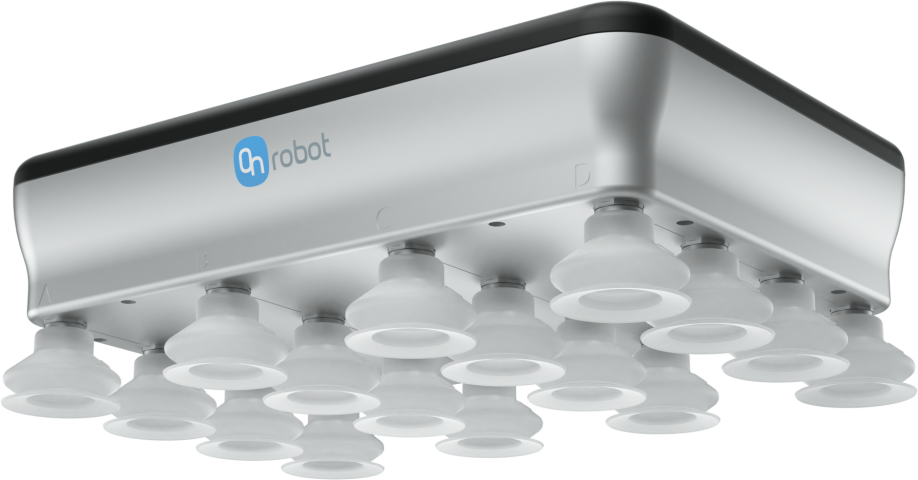
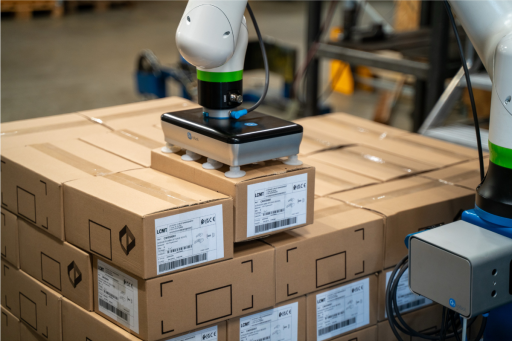
Porous cardboard can leak air and reduce vacuum performance. The VGP20 provides up to 48 L/min total airflow across four channels, helping maintain the grip on cardboard and other workpieces where lower-flow systems may struggle.
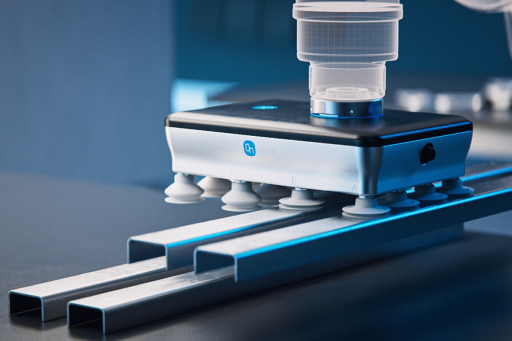
Sixteen standard cup positions are divided across four independently controlled channels. Use only the zones that contact the workpiece, adjust the cup layout, or control channels separately for different box sizes and pickup patterns.
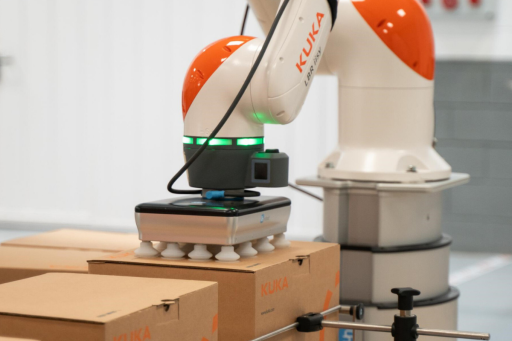
For standard cardboard, the typical maximum payload is 10 kg using all available suction cups. Loads up to 20 kg require low acceleration and may depend on the workpiece, cup layout, vacuum level, and optional equipment.


Use four channels and up to 48 L/min total airflow to handle cardboard and other workpieces where leakage affects vacuum performance.
Activate only the channels that contact the workpiece, helping the gripper adapt to changing box sizes, surfaces, and pickup patterns.
The standard gripper provides 16 cup positions. An optional high-payload bracket adds 24 positions and connections for external vacuum assistance when the application requires it.
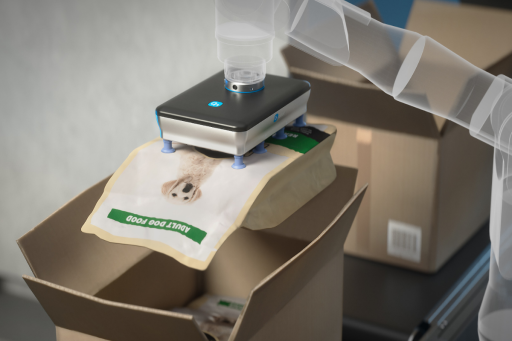
Automate palletizing, packaging, and material handling for cardboard boxes and other vacuum-suitable parts. Four channels, configurable cup positions, airflow control, and monitoring help adjust the grip for changing sizes, surfaces, and pickup patterns.
Tell us about your boxes, surfaces, payload, robot, and cycle requirements. Our local expert can help assess cup layout, vacuum performance, and whether optional high-payload equipment is appropriate.