Use internal or external gripping with either normal grip for known diameters and forces above 300 N, or flexible grip for varying diameters with force up to 300 N.

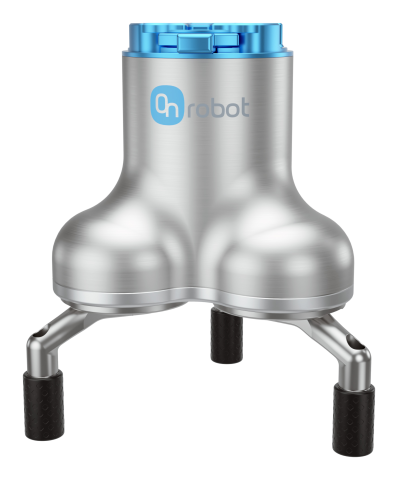
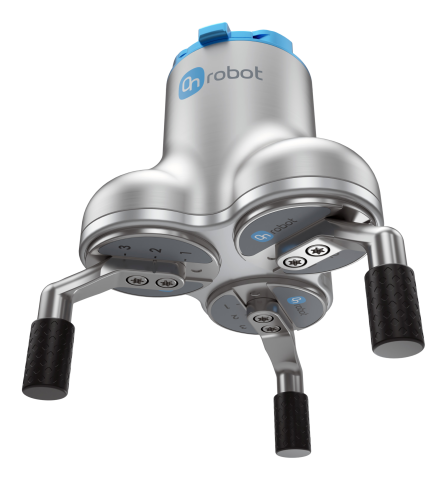
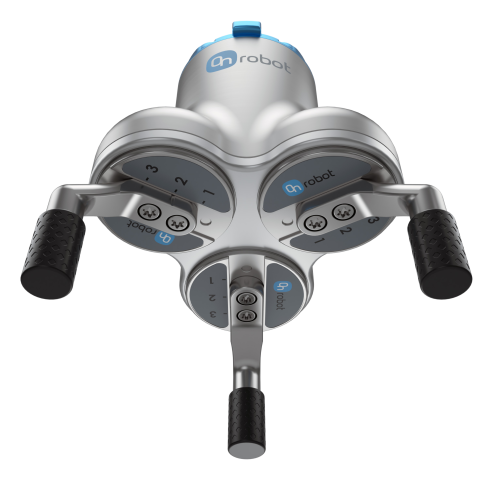
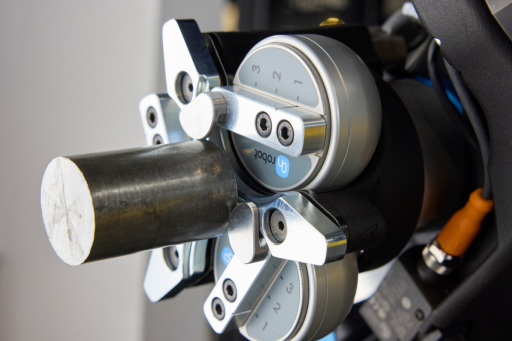
Three synchronized fingers centre large round workpieces for stable handling and accurate placement. The 3FG25 supports form-fit payloads up to 25 kg and force-fit payloads up to 15 kg.
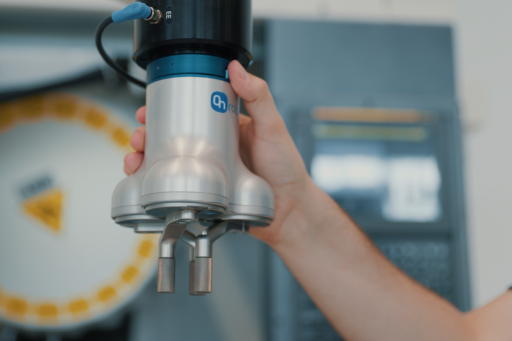
Use internal or external gripping with either normal grip for known diameters and forces above 300 N, or flexible grip for varying diameters with force up to 300 N.
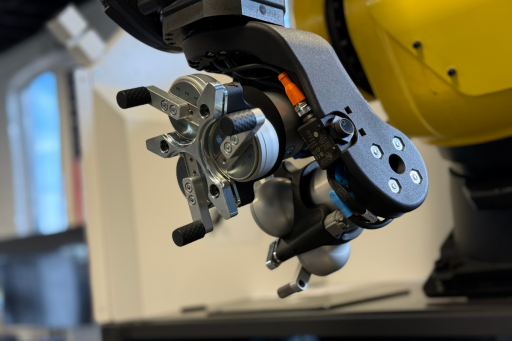
IP67 protection helps the electric gripper operate around coolant and flying chips. A mechanical brake holds the applied gripping force without power consumption and retains the workpiece if power is lost.


Three synchronized fingers centre round workpieces as they grip. Form-fit handling supports payloads up to 25 kg, while force-fit gripping supports up to 15 kg when the application conditions match the datasheet limits.
Normal grip is designed for known diameters and provides up to 450 N. Flexible grip handles unknown or varying diameters with force up to 300 N. Both methods support internal and external gripping.
The IP67-rated design is built for machining workshops where coolant and chips are present. A brake maintains the applied gripping force without continuous power and retains the workpiece during power loss.

Load and unload large metal workpieces in demanding machining environments. The 3FG25 combines centric three-finger positioning, internal and external gripping, up to 450 N gripping force and IP67 protection.
Tell us about the workpiece, machine environment and gripping sequence you want to automate. Our local expert will help you assess the 3FG25 for your robot and application.