
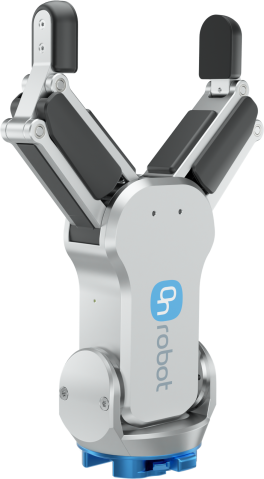
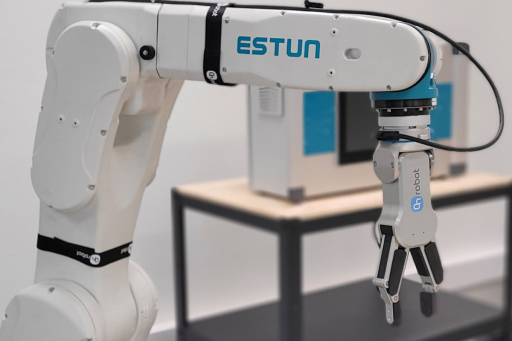
The RG6 combines a 160 mm adjustable stroke with 25–120 N programmable gripping force, so one tool can handle a wide range of larger part sizes and shapes. Internal and external gripping plus customizable fingertips make it easier to adapt the gripper to the workpiece.
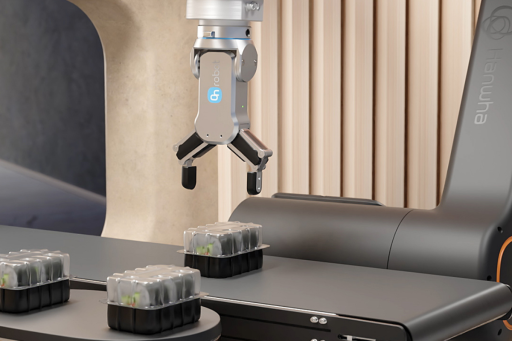
Automatic tool center point and payload calculations reduce manual setup work when deploying or changing the application. Integrated software keeps gripping parameters inside the robot program, making changeovers faster and easier to repeat.
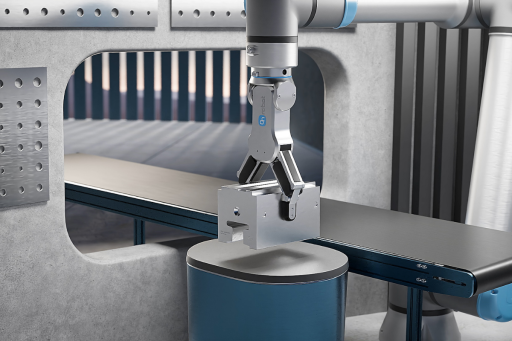
Built-in grip detection reports when a part is gripped, lost, or continuously held, and can measure part width. This gives the robot useful process feedback without adding separate sensors or custom detection logic.


The RG6 is designed for larger and heavier parts, with up to 6 kg force-fit payload, up to 10 kg form-fit payload, a 160 mm adjustable stroke, and 25–120 N gripping force. Customizable fingertips and internal or external gripping help one tool cover more workpieces.
Automatic TCP and payload calculation, automatic depth compensation, and integrated software remove several manual setup steps. Operators can update gripping parameters in the robot program and redeploy the application without rebuilding the tooling.
Automatic grip detection helps the robot respond when a part is gripped, lost, or continuously held. The RG6 can also measure part width, adding useful feedback for machine tending, material handling, pick and place, and assembly tasks.
Automate machine tending, material handling, pick and place, and suitable assembly tasks involving larger or heavier parts. Adjustable stroke and force, customizable fingertips, and built-in detection help the RG6 adapt when parts and production requirements change.
Tell us about your parts, robot, and production needs. Our local expert will help assess the setup, compatible robot options, and the right path to deployment.