Configure the magnetic force in ten steps to match different part sizes, weights and process needs. Adjustable force supports tasks such as separating thin metal sheets one at a time.

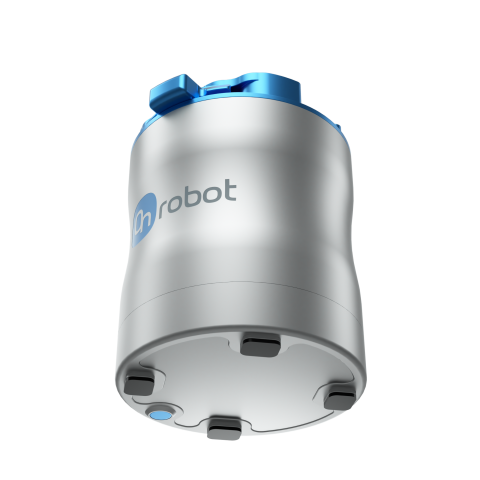
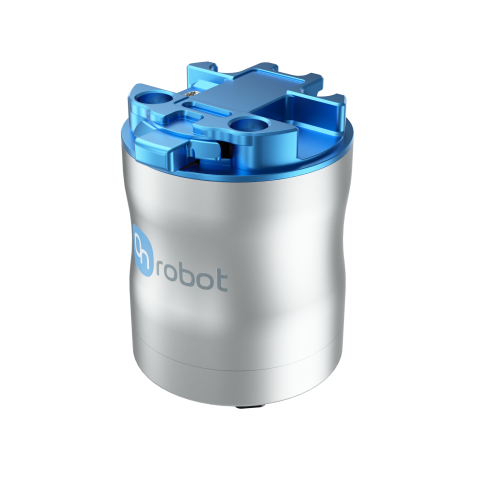
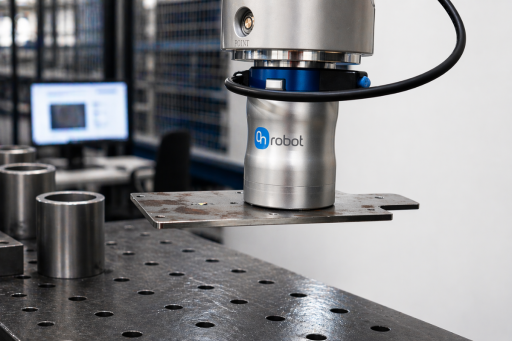
The MG10 grips ferromagnetic workpieces without requiring a sealed surface. It can handle perforated, abrasive, dusty and unusually shaped metal parts while leaving no vacuum-cup marks.
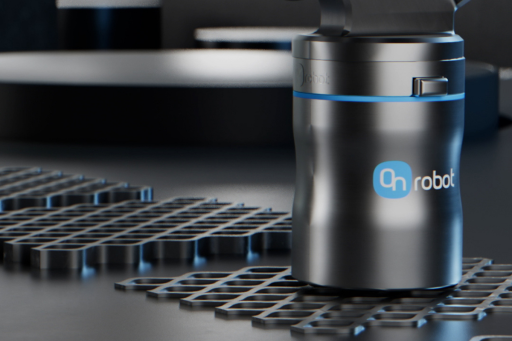
Configure the magnetic force in ten steps to match different part sizes, weights and process needs. Adjustable force supports tasks such as separating thin metal sheets one at a time.
The gripper maintains its magnetic hold if power is lost or an emergency stop occurs. This helps prevent a held workpiece from being released unexpectedly during an interruption.


Magnetic gripping does not depend on an airtight surface. The MG10 can handle perforated, dusty, abrasive and irregular ferromagnetic parts, including metal sheets and blanks used in machine-tending processes.
Magnetic force can be configured in ten steps, helping the gripper match different workpieces and separate thin sheets. Pads, cylindrical fingertips and custom fingers extend the mechanical setup for specific parts.
A built-in proximity sensor supports part-presence detection with compatible finger setups. If power is interrupted or an emergency stop occurs, the MG10 maintains its magnetic force and continues holding the workpiece.
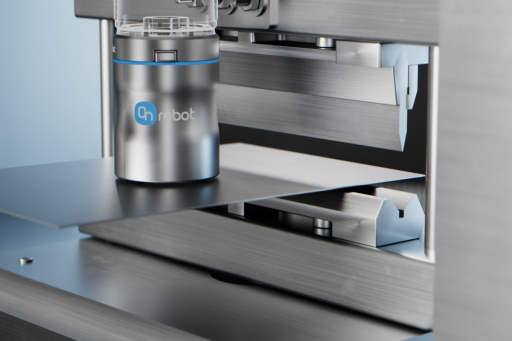
Automate press tending, bending, destacking and material handling for ferromagnetic workpieces. The MG10 combines adjustable magnetic force, built-in part detection and power-loss hold in a compact electric gripper that does not require compressed air.
Tell us about the metal parts and process you want to automate. Our local expert will help you assess the MG10 for your robot, workpiece and application.