OnRobot
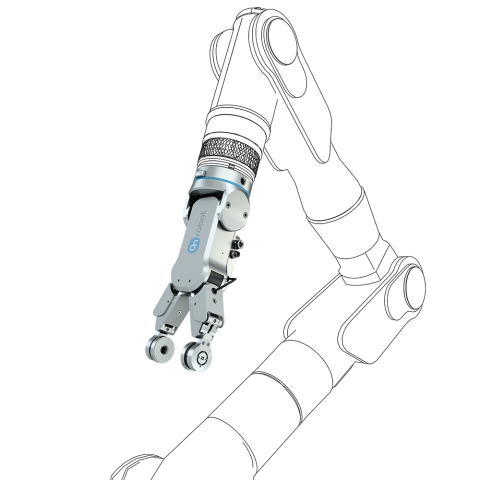
RG2-FT
RG2-FT
RG2-FT
Force/torque sensing · Proximity sensing · Electric gripping

RG2-FT

Intelligent gripper with force, torque and proximity sensing at the fingertips

  • Integrated sensing provides real-world data for Physical AI model validation and training, while improving handling reliability
  • Reduce defects and improve production quality with precise sensing for delicate pick-and-place tasks
  • Enable insertion and mounting tasks out-of-the-box to reduce operation costs with added sensing capabilities directly in the fingertips
Up to 2 kg Force-fit payload
Up to 4 kg Form-fit payload
100 mm Adjustable stroke
3-40 N Adjustable gripping force
150 Hz Sensor sampling frequency
0.98 kg Gripper weight
Physical AI
Collect force, torque, presence and distance data directly at the fingertips to train and validate Physical AI models for robotic manipulation.
Delicate handling
Handle fragile and variable parts with adjustable gripping force and fingertip sensing. Monitor grip conditions to improve reliability and help reduce defects.
Insertion and assembly
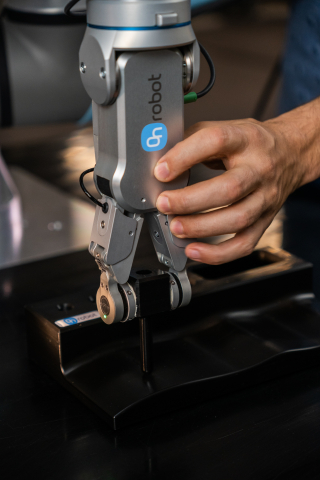
Use contact and alignment feedback during insertion and mounting. Detect unexpected resistance and help verify part seating when conditions vary.

Features and Advantages

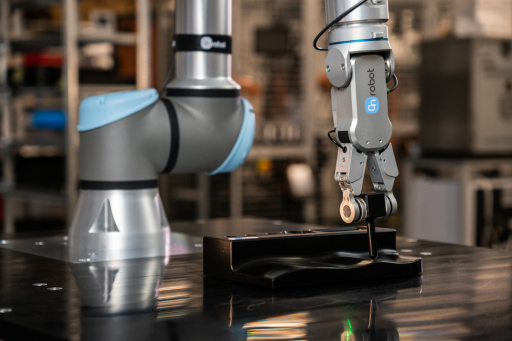
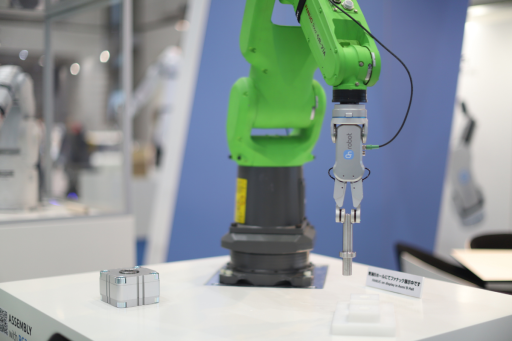
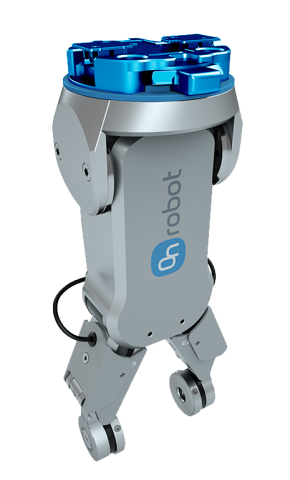
RG2-FT is a unique version of the RG series with integrated force/torque sensors and a proximity sensor at the fingertips, enabling you to accurately detect the position of objects. This is a state-of-the-art gripper with an enhanced sensing ability and added intelligence, capable of controlling the robot and itself to achieve what the operator would like it to do, even when the exact parameters cannot be programmed in advance. This enables true collaboration with human operators, supporting them like a co-worker would and ensuring precision handling hour after hour. The same contact-rich data, force, torque, presence, and distance, also makes the RG2-FT a practical sensing foundation for Physical AI, giving model builders real-world data captured directly at the point of contact.
01

A sensing foundation for Physical AI

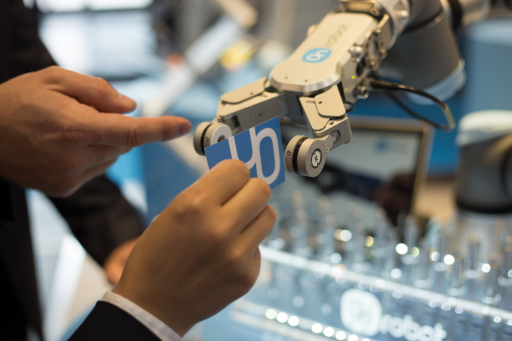
Physical AI models need data from real-world interaction. RG2-FT captures force, torque, presence and distance directly at the fingertips, providing contact-rich input for model training and validation.

Two 6-axis force/torque sensors, one per finger, measure forces and torques at each point of contact. Two proximity sensors detect object presence and distance before contact. Together, they give robotics teams feedback for studying approach, grasping and manipulation.
150 Hz Force/torque and proximity feedback
02

More reliable, precise handling

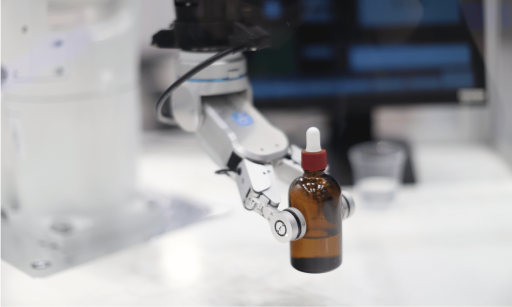
Improve delicate pick-and-place with feedback about the part and the grip. Proximity sensing helps detect objects before contact, while force/torque sensing and grip monitoring help identify changes during handling. Grip and slip detection can confirm grasping, monitor grip loss and indicate the risk of slipping.

Adjust gripping force from 3 to 40 N and use up to 100 mm of stroke to accommodate different parts. Customizable fingertips adapt the contact surface to the workpiece, supporting reliable handling of varied sizes and shapes while helping reduce defects.

3-40 N Adjustable gripping force
03

Simplify insertion and mounting

Insertion and mounting depend on what happens at contact. Integrated fingertip sensing helps the robot detect contact, alignment and unexpected resistance, supporting tasks where exact positions and conditions can vary between cycles.

Use this feedback to guide insertion and help determine whether a component is seated correctly. Pre-integrated software simplifies setup and programming, reducing the integration effort needed to put the gripper and its sensing capabilities to work.

0.1 mm Typical finger-position resolution
ABB Doosan Fanuc Hanwha Jaka Kassow Robots Kawasaki Robotics Kuka Nachi Techman Universal Robots Yaskawa Denso Elite Robots Epson Schneider Electric Omron ABB Doosan Fanuc Hanwha Jaka Kassow Robots Kawasaki Robotics Kuka Nachi Techman Universal Robots Yaskawa Denso Elite Robots Epson Schneider Electric Omron
Features

Sensing and gripping in one tool

Each RG2-FT finger has a 6-axis force/torque sensor that measures forces and torques at its own point of contact. This gives the robot feedback during gripping, insertion and assembly, helping it detect contact and respond when resistance or alignment changes.

A proximity sensor on each finger detects object presence and measures distance before contact. Combining approach sensing with contact feedback supports tasks where part positions vary and fixed coordinates alone do not provide enough information.

  • Two 6-axis force/torque sensors, one per finger

  • Two proximity sensors for presence and distance measurement

  • 150 Hz sampling for force/torque and proximity sensing

  • Feedback before contact and throughout interaction

RG2-FT provides force, torque, presence and distance data directly at the fingertips. Robotics teams can use this contact-rich output to train and validate Physical AI models, connecting robot movements with what happens when the tool approaches, grasps and interacts with an object.

The same sensing capabilities support everyday handling. Grip and slip detection can confirm grasping, monitor grip loss and indicate the risk of slipping, helping the application respond to changing grip conditions when handling delicate or variable parts.

  • Collect real-world interaction data for Physical AI

  • Confirm grasping and monitor grip conditions

  • Detect grip loss and the risk of slipping

  • Support more reliable delicate pick-and-place

Customizable fingertips let you adapt the contact surface to workpieces of different sizes and shapes. Combined with adjustable stroke and gripping force, this gives you flexibility to handle varied parts while matching the grip to the application.

Pre-integrated software simplifies installation and programming of the gripper and its sensing functions. By combining electric gripping and fingertip sensing in one tool, RG2-FT helps reduce integration complexity for handling, insertion and assembly tasks.

  • Adapt fingertip geometry to the workpiece

  • Adjust gripping force from 3 to 40 N

  • Use up to 100 mm of adjustable stroke

  • Simplify setup with pre-integrated software

Why RG2-FT

Give your robot feedback at the point of contact

RG2-FT combines electric gripping with force/torque and proximity sensing at both fingertips. It helps the robot detect objects before contact and monitor interaction as it grasps, moves or inserts a part. The result is useful feedback for delicate handling and assembly, alongside real-world data for Physical AI model training and validation.

Up to 2 kg Force-fit payload
100 mm Adjustable stroke
150 Hz Sensor sampling frequency
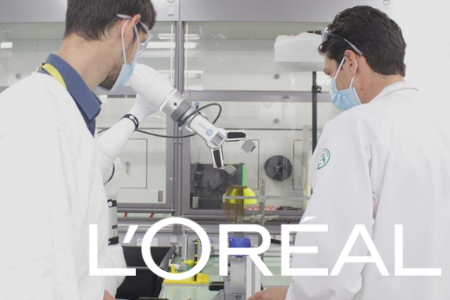
L'Oréal automates hair research centre
Material Handling

L'Oréal automates hair research centre

175 → 504 Formulas tested per week
L'Oréal is a French industrial group specializing in cosmetic products, now the world leader in the cosmetics industry.

In 2012, the brand opened the largest hair research center in the world, which is located in Saint-Ouen, France. Nearly 500 researchers work over three stories, formulating new shampoos, treatments, styling products, and hair colors based on scientific advances and hair types. They develop, create, and closely monitor the beauty needs and aspirations of consumers.
Downloads & resources

Everything you need to get started

Technical resources for evaluating, specifying and integrating the RG2-FT.
Datasheet
Technical specifications, dimensions and sensor performance data for the RG2-FT.
Download →
Step files
RG2-FT models for planning mechanical integration.
Download →

What could fingertip sensing bring to your application?

Tell us about your workpiece, robot and task, whether you are collecting data for Physical AI, handling delicate parts or automating insertion and assembly. Our local expert can help assess sensing requirements, fingertip design and integration.

Talk to an expert

Choose your language

Americas

English Português Español

Asia

简体中文 繁体中文 日本語 한국어 ภาษาไทย Tiếng Việt

Europe

English Čeština Dansk Nederlands Suomi Français Deutsch Magyar Italiano Norsk Polski Português Română Español Svenska Türkçe
English